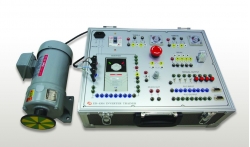
Motor / Dynamometer Trainer Unit MG-5219

Cod: MG-5219


Brosura produs PDF, 0.51 Mb

Descriere

MOTOR SECTION

  • Winding Type
  • Squirrel cage rotor
  • Split-phase stator
  • Speed : 1725 RPM
  • Input Voltage : AC 110V, 60Hz
  • Input Current : 6.6A
  • Number of Poles : 4 poles
  • Horsepower : 1/3 HP
  • Start Capacitor : 180~220µF
  • Indication Meter : 1-current, 1-voltage, 1-RPM(digital), 1-watt
  • Overload Trip : 7A(Approx.) 
  • Shunt Rheostat : 0~300?, 50W
  • General Output : 120V DC, 2.4A
  • Exciting Power : DC 0~120V, 1A
  • Indication Meter : 2-current, 2-voltage
  • Overload Trip : 4A Approx.
  • Load Resistance : 48?~480?, 500W


GENERAL CHARACTERISTICS

  • Main Input Voltage : AC 220V, single phase
  • Rating : 30 minutes
  • System Size : 960(W) x 860(H) x 475(D)mm
  • Weight : 80kg


GENERATOR SECTION

  • Winding Type : Shunt(Separator)
  • Speed : 1800 RPM
  • Horse Power : HP
  • Number of Poles : 2 poles


ACCESSORIES

  • Patch Cords(ø4 Plug) : 1set
  • AC Power Cord : 1ea
  • Experimental  Manual : 1ea
 

Accesorii standard


Alte produse ED

PORTABLE PLC TRAINER ED-4260P

• Composed of essential devices for Programmable Logic Controller I/O commands
• LD (Ladder Diagram), IL (Instruction List), SFC (Sequential Function)
• Built-in Simulator to train on the encoder’s principle and functions
• Stepping motor and DC motor installed as standard (forward/reverse rotation, linear movement)
• Capable of network configuration by CPU and Remote I/C Link


OP-AMP CIRCUIT TRAINER ED-6000

• OP-Amp. characteristics and various appplication circuits
• Main Frame contains DC Power Supply, AF Signal and Frequency Counter


SERVO UNIT TRAINER ED-4270M

• Experiments on various types of special control unit
• Characteristics of Servo Motor and setup of Servo Driver
• Essential components in automation using a PLC position module
• 4mm banana jack to increase wiring capability


INTELLIGENT EDUCATION ROBOT PLATFORM ED-7270

• Ideal for the Ubiquitous and Home Network based experiments
• Home security experiments on utilization of its unattended security function
• Robot control API using Visual C++ and control functions by Visual Basic Scripter
• Next Generation Cell(Lithium Lon) - compact size and increase in life time


FM TRANSCEIVER TRAINER ED-3600

• Realistic Simulation of FM stereo broadcast
• Graphical layout of block diagrams, display elements and test points
• Covers the principles of FM stereo encoder and decoder
• Experiments on stereo amplifier (equalizer, tone control, pre-amp, etc.)


LOGIC CIRCUIT LAB ED-1006

• Hexadecimal number indicators
• Selectable pulse outputs
• Built-in DC power supp


INVERTER MOTOR TRAINER ED-4304

• Practical training on inverter and 3-phase induction motor operations
• Control experiments using a PLC module (in use of D/A module)
• Feasible contact-type PLC control
• Carrying case type structure for convenient storage and mobility


6-AXIS MULTI JOINT ROBOT TRAINER ED-VP6

• Experiments on the industrial robot being used in real life
• Teaching pendant in 7.5wide color touch panel
• Standard language for the international industrial robot
• Simulation software in three dimension


TELECOMMUNICATION TRAINER ED-2960

• 7 experimental modules with a mainframe console
• Harmonic Analysis and Superheterodyne Receiver experiments
• PCM(TDM), Sample Hold, and Delta Modulation experiments


ADSL TRAINING SYSTEM ED-NET-2

• Study of functions, characteristics, installation, repair and maintenance of basic ADSL components such as Telephone Exchange, Splitter, DSLAM, ADSL Modem, HUB and LAN Card
• Network structure through interworking experiments with Internet and capability of Internet usage and simple programming
• Capable of interworking experiments with ED-NET-3(LAN Training System)