Embedded & Dsp Design Platform ED-DAVINCI

Cod: ED-DAVINCI


Brosura produs PDF, 0.73 Mb
 

Descriere

Features:

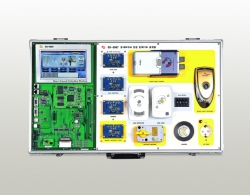
  • One-stop training kit for embedded system, DSP and FPGA
  • Texas Instruments’ Davinci processor containing the built-in ARM Core and DSP Core
    • 297MHz ARM926EJ-S™ ARM Core
    • 594MHz TMS320C64x+™ DSP Core
  • ALTERA Cyclone 120,000Gate, a FPGA chip, mounted for interlocking experiments on SoC
  • Embedded LINUX for basic to advanced courses
  • 7" Wide TFT LCD, 10/100 Ethernet 1Port, Serial 1Port, SD/MMC,  ATA and other interfaces
 

Alte produse ED

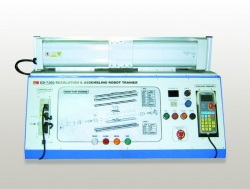
ASSEMBLING ROBOT TRAINER ED-7300

• Disassembly and assembly practices for the robot actuators
• Utilization of a robot being used in the industry, so to apply a job site after graduation
• Simulation software provided to make assembly or disassembly easily
• Enables basic operation and testing practices on the assembled unit using a controller


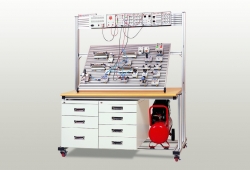
PNEUMATICS TRAINER ED-7860

• Convenient parts fixation by ‘one-touch lever’ bases and aluminum profile structure
• Efficient space utilization by mounting parts horizontally/vertically
• A complete pneumatic training system to help achieve advanced level of skills and obtain pneumatic engineering related licensesOver


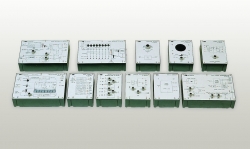
DIGITAL COMMUNICATION TRAINER ED-2970

• Modularized by the function of digital communication circuits
• FSK, ASK, PSK, QPSK and digital communication principles
• 12 types of modules including a power supply unit


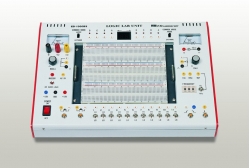
LOGIC LAB UNIT ED-1000BS

• Hi/Lo Logic Switch
• BCD hexadecimal indication LED
• Built-in DC power supply(+5V,+9V,±15V)
• Voltage and current meter
• DC overload alarm and indication
• Variable and single pulse generator


EMBEDDED BASED HOME NETWORK TRAINER ED-5967

• Home network control in liaison with Embedded PXA 255/270/272/320
• Power line communication and ZigBee modules with Multi Port in use together
• Embedded


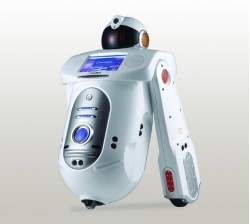
INTELLIGENT EDUCATION ROBOT PLATFORM ED-7270

• Ideal for the Ubiquitous and Home Network based experiments
• Home security experiments on utilization of its unattended security function
• Robot control API using Visual C++ and control functions by Visual Basic Scripter
• Next Generation Cell(Lithium Lon) - compact size and increase in life time


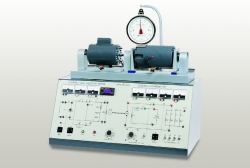
MOTOR / DYNAMOMETER TRAINER UNIT MG-5219

• Measurement of induction motor’s power efficiency
• How to use electro-dynamometer
• Torque Measurements by dynamometer
• Use of separately excited DC generator


STEPPING MOTOR TRAINER ED-4301

• Graphical display of functonal block diagram on the system suface
• Real-time monitoring and control by PC Control Program
• LM Guide and Rotary Encoder for position control
• Displays moving distance and angle data using LCD


4-AXIS SCARA ROBOT TRAINER ED-HS4

• Experiments on the industrial SCARA robot
• Teaching pendant in 7.5wide color touch panel
• Standard language for the international industrial robot
• Simulation software in three dimension


FUEL CELL TRAINER ED-9741

• Testing of load for maximum four fuel cell at the same time
• Removable type of electrical dissolution and fuel cell from main body
• Monitoring through LabVIEW program