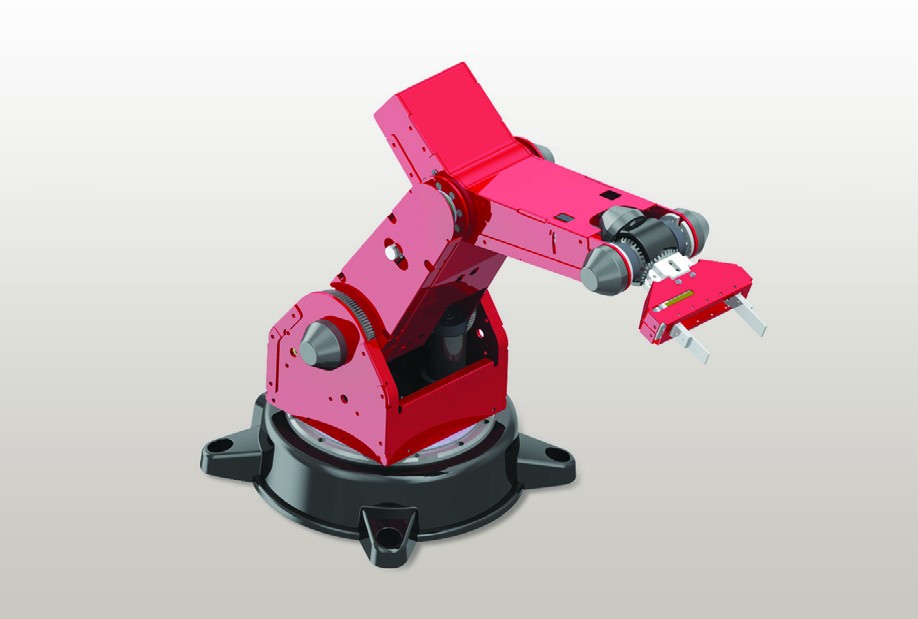
5-axis Arm Robot Trainer ED-7255

Code: ED-7255


Datasheet PDF, 0.47 Mb

Description

EXPERIMENTS

  • Introduction to the System
    • Basic Configuration
    • Description of components
    • Overview of Program
    • Architecture
    • Installation
  • Program Composition
    • Menu and Toolbar
    • View and Windows
    • Simulator and Screen control
    • Industrial language editor
  • Arm Viewer and Robot Manipulation
    • How to use "3D Arm Viewer"
    • Manual mode for controlling the robot
    • Storage and utilization of the position data
  • Programming
    • How to use Program Editor
    • Program syntax
    • Programming
    • Program execution and debugging
  • Robot Simulation
    • Virtual simulation and robot manipulation methods
    • Basic experiments 1
    • Basic experiments 2
    • Basic experiments 3
  • Robot Control Basic Experiment
    • Position transfer methods
    • Velocity transfer methods
    • Position determination methods
    • How to use "Teach Pendant"
  • Applications for Robot Manipulation
    • Accurate transfer through block repetitions
    • Grip and transfer for a certain object
    • Position transfer for a certain object
    • Repetitive operation and simulation-linked transfer


Features:

  • Consists of one gripper and 5-axis vertical multi joints
  • Absolute-type RVDT Position Sensor applied to each axis and requires no Limit switch
  • High performance CPU enables real-time control of each axis
  • PID gain tuning and real-time control
  • Emergency switch on the robot controller and teaching pendant
  • Control by USB and Ethernet interface
  • Expandible 2-axis and digital or analog I/O port
  • 3D graphic simulation and real-time connectivity with a real robot


More products ED

COMPUTER BASED INSTRUMENT SYSTEM CBIS-1400

• PC-based multi-function instrument for electricity/electronics and other experiments
• Digital Storage Oscilloscope with the 2-channel simultaneous 50MS/s sampling rate
• Spectrum Analyzer functions using Digital Storage Oscilloscope(DSO)
• Variable Power Supply(VPS), Function Generator(FG), Analog Output and Digital Output
• Analysis of collected data on PC through the modules of DSO, DMM, FC and Analog/Digital Input
• Numerical and graphical indication of the data measured and analyzed in real time


OMNI-DIRECTIONAL MOBILE ROBOT ED-7275

• Omni-directional robot system
• Microprocessor based control command as for simple use
• Floor detecting sensor and forward area detecting distance sensor as mounted
• Mountable expansion by adding the optional ultrasonic sensor and infrared sensor


LAN TRAINING SYSTEM ED-NET-3

• Panel type structure for good grasp of entire network configuration
• Learning about the functions and characteristics of basic network equipments such as NIC, HUB, Router and DSU, plus installation and maintenance
• Interlocking experiments with Internet for clear understanding a real network
• Capable of conneting to the open network on campus


STEPPING MOTOR TRAINER ED-4301

• Graphical display of functonal block diagram on the system suface
• Real-time monitoring and control by PC Control Program
• LM Guide and Rotary Encoder for position control
• Displays moving distance and angle data using LCD


FM TRANSCEIVER TRAINER ED-3600

• Realistic Simulation of FM stereo broadcast
• Graphical layout of block diagrams, display elements and test points
• Covers the principles of FM stereo encoder and decoder
• Experiments on stereo amplifier (equalizer, tone control, pre-amp, etc.)


LED LAMP TRAINER ED-9810

• Practice basic method how to operate such as basic peration, Constant voltage, Constant current, serial connection, and arallel connection
• Brightness control, Color control, and lighting
• Simulation for Steady/PWM


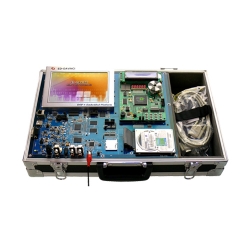
EMBEDDED & DSP DESIGN PLATFORM ED-DAVINCI

• One-stop training kit for embedded system, DSP and FPGA
• 7" Wide TFT LCD, 10/100 Ethernet 1Port, Serial 1Port, SD/MMC, ATA and other interfaces


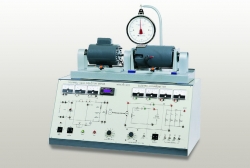
MOTOR / DYNAMOMETER TRAINER UNIT MG-5219

• Measurement of induction motor’s power efficiency
• How to use electro-dynamometer
• Torque Measurements by dynamometer
• Use of separately excited DC generator


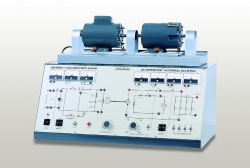
SQUIRREL CAGE INDUCTION MOTOR/ DC GENERATOR MG-5212

• Start and load characteristics of squirrel cage induction motor
• Alteration of the rotative directions of squirrel cage Induction Motor
• Slip speed and torque of induction motor
• Induction motor’s no-load power factor and load power facto


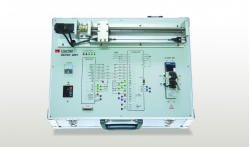
SERVO UNIT TRAINER ED-4270M

• Experiments on various types of special control unit
• Characteristics of Servo Motor and setup of Servo Driver
• Essential components in automation using a PLC position module
• 4mm banana jack to increase wiring capability