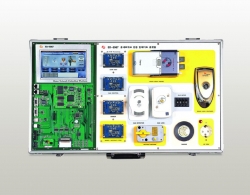
Intelligent Education Robot Platform ED-7270

Code: ED-7270


Datasheet PDF, 1.08 Mb

Description

EXPERIMENTS

1st STEP

  • Concept and definition of the Intelligent Robot
  • Structure and principle of the Intelligent Robot


2nd STEP

  • Principle and practice for the Intelligent Robot’s sensor
  • Voice recognition and image sensor
  • Programming through the dialogue-type language


3rd STEP

  • Operation of the Dialogue-based Robot
  • Ubiquitous environment based control
  • Autonomous movement and object recognition


4th STEP

  • Practice on movement along optimized routes
  • Practice on remote network control


Features:

  • Insight into the Intelligent Robot and step-by step practices
  • Various services through the functions of ZigBee and RFID Reader
  • Recognition of the robot’s position and direction
  • Various training contents using the dialogue language(programs)
  • Image processing by the Fan/Tilt USB Camera
  • Human-friendly design to interact with the human being
  • Ideal for the Ubiquitous and Home Network based experiments
  • Home security experiments on utilization of its unattended security function
  • Robot control API using Visual C++ and control functions by Visual Basic Scripter
  • Next Generation Cell(Lithium Lon) - compact size and increase in life time


More products ED

NEW & RENEWABLE ENERGY TRAINER ED-9720

• Conversion experiments on the produced energy(power production/processing)
• Characteristics of Solar Cell module’s voltage and current
• Alarm beep for wrong wire placement
• Voltmeter and ammeter as included for measuring AC and DC
• Control by PC and waveform and graph output


PNEUMATICS TRAINER ED-7860

• Convenient parts fixation by ‘one-touch lever’ bases and aluminum profile structure
• Efficient space utilization by mounting parts horizontally/vertically
• A complete pneumatic training system to help achieve advanced level of skills and obtain pneumatic engineering related licensesOver


OPTICAL COMMUNICATION TRAINER ED-2980

• E/O and O/E conversion and characteristics
• Optical PCM communication(trasmission&reception)
• Optical Data communications using personal computer
• DC power supply, a roll of fiber cable and the microphone included as peripherals


WOUND-ROTOR INDUCTION MOTOR/ DC GENERATOR MG-5213

• Load characteristics of shunt-wound and compound generators
• Generator’s speed and output by winding type
• Loss and efficiency comparisons by winding type


BLOCK MODULAR PRODUCTION SYSTEM ED-9150

• Small size type suitable for traning on automation system’s installation and operation
• Mechanism and installation methods through assembly and disassembly per process
• Enhancement of application programming techniques through PLC control


6-AXIS MULTI JOINT ROBOT TRAINER ED-VP6

• Experiments on the industrial robot being used in real life
• Teaching pendant in 7.5wide color touch panel
• Standard language for the international industrial robot
• Simulation software in three dimension


EMBEDDED BASED HOME NETWORK TRAINER ED-5967

• Home network control in liaison with Embedded PXA 255/270/272/320
• Power line communication and ZigBee modules with Multi Port in use together
• Embedded


FM TRANSCEIVER TRAINER ED-3600

• Realistic Simulation of FM stereo broadcast
• Graphical layout of block diagrams, display elements and test points
• Covers the principles of FM stereo encoder and decoder
• Experiments on stereo amplifier (equalizer, tone control, pre-amp, etc.)


PC BASED RFID TRAINER ED-1450

• The electronic manual operable on PC comes with ED-1450 and e-learning is optimized by remote control of student’s operating program and evaluation of student’s online report in real time.
• Through DS-1410, it provides Variable Power Supply(VPS), Function Generator(FG), Analog Output, Digital Output needed for experiments.


MOTOR / DYNAMOMETER TRAINER UNIT MG-5219

• Measurement of induction motor’s power efficiency
• How to use electro-dynamometer
• Torque Measurements by dynamometer
• Use of separately excited DC generator