Assembling Robot Trainer ED-7300

Code: ED-7300


Datasheet PDF, 0.66 Mb
   

Description

EXPERIMENTS

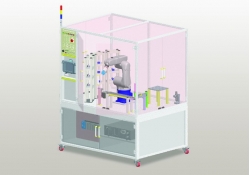
  • Alignment of the disassembled components
  • Operating principle of the ball screw and LM Guide
  • Understanding of the robot’s structure in detail
  • Enhancement of manufacturing skills through assembly and disassembly


Features:

  • Disassembly and assembly practices for the robot actuators
  • Utilization of a robot being used in the industry, so to apply a job site after graduation
  • Simulation software provided to make assembly or disassembly easily
  • Enables basic operation and testing practices on the assembled unit using a controller
 

More products ED

CDMA TRAINING KIT ED-2945

• Rich experiments devoted to IS95 standard
• Easy-to-follow structure as main functions are itemized in modules


6-AXIS MULTI JOINT ROBOT TRAINER ED-VP6

• Experiments on the industrial robot being used in real life
• Teaching pendant in 7.5wide color touch panel
• Standard language for the international industrial robot
• Simulation software in three dimension


POWER ELECTRONICS TRAINER ED-2040

• Covers essential circuits needed to practice power electronics circuits
• Modular type with aluminum carrying case
• Optional rack to be customized upon requst


PNEUMATICS TRAINER ED-7860

• Convenient parts fixation by ‘one-touch lever’ bases and aluminum profile structure
• Efficient space utilization by mounting parts horizontally/vertically
• A complete pneumatic training system to help achieve advanced level of skills and obtain pneumatic engineering related licensesOver


MOTOR / GENERATOR TRAINER UNIT MG-5216

• RIM’s no-load power factor and load power factor
• Load characteristics of separately excited DC shunt-wound generator
• No-load saturation characteristics of generator
• DC shunt-wound generator’s loss and power factor


HOME NETWORK DESIGN PLATFORM ED-5965

• Designed to help develop network devices on the basis of Lon Protocol
• Control of each device installed in the field through power line communication
• Related experiments through Neuron C and MICOM programming
• Home network control in utilization of LabVIEW


4-AXIS RECTANGULAR COORDINATES ROBOT TRAINER ED-XYZ

• Experiments on the 4-axis Cartesian robot
• Teaching pendant in 7.5wide color touch panel
• Standard language for the international industrial robot
• Simulation software in three dimension


DC SERVO TRAINER ED-4400B

• Analog feedback loop & DC servo system
• Modularized by the function of servo circuits
• Overload protection for the servo amp's and power supply's output


AM TRANSCEIVER TRAINER ED-3400

• HF band(3.5~12MHz)
• Transmitter and Receiver modules for each circuit stage
• Graphical latour of the block diagrams, plus LEDs and test points
• Covers Push-to-Talk and helps understand short wave communications


BLOCK MODULAR PRODUCTION SYSTEM ED-9150

• Small size type suitable for traning on automation system’s installation and operation
• Mechanism and installation methods through assembly and disassembly per process
• Enhancement of application programming techniques through PLC control